How can an AI model think falsely - and why is this dangerous for robots?
Research shows that even advanced language models (LLMs) are not always reliable in their reasoning. In the case of complex tasks, their reliability - i.e., the extent to which they actually reflect the decision-making process - degrades by 44%. This means that even if a model seems to reason logically step by step, its conclusions may be completely false. For autonomous robots that make decisions in real time - e.g., in warehouses, medical facilities, or industry - such false reliability can lead to errors with significant consequences: from damage to goods to dangerous behavior towards humans.
In the context of robotics, where decisions are often critical for safety and efficiency, the problem is not just theoretical. When an AI model "thinks" too quickly or without proper control, it can generate reasoning that sounds logical but is completely different from the actual decision-making process. This phenomenon is called hallucination - i.e., generating false or untrue conclusions. Without appropriate verification mechanisms, such errors can be difficult to detect and lead to serious system failures.
Research results show that only 25-39% of the time do LLM models actually reflect their decisions in a transparent way. This means that most of their reasoning is opaque - which is critical for systems that must be safe and responsible. Direct application of such models in robotics without additional control can lead to situations where a robot makes a decision based on false reasoning, and the user does not know what happened. Therefore, systems are needed that not only support reasoning but also verify and control it.
CT-SAFR: multi-layer verification for safe autonomy
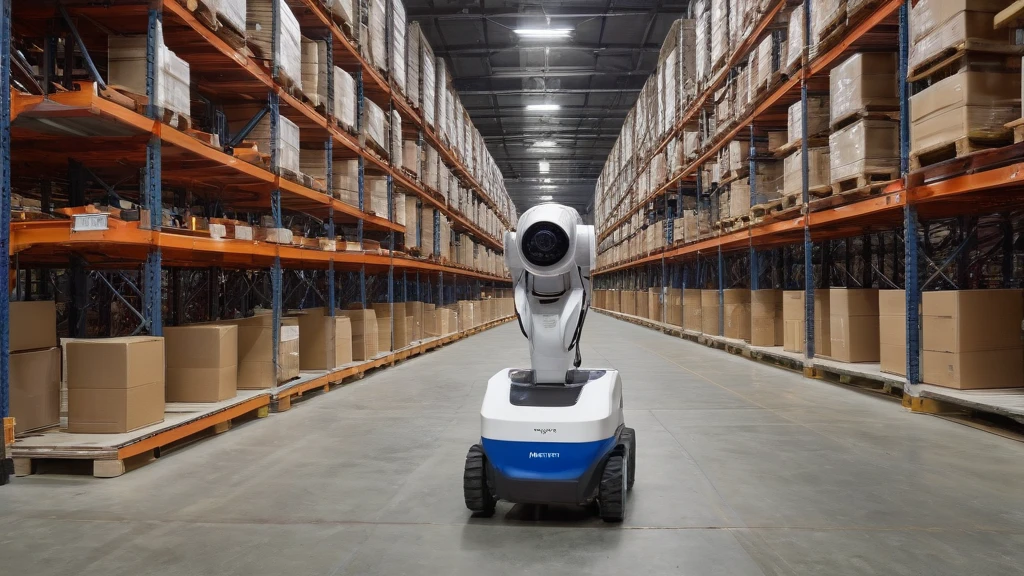
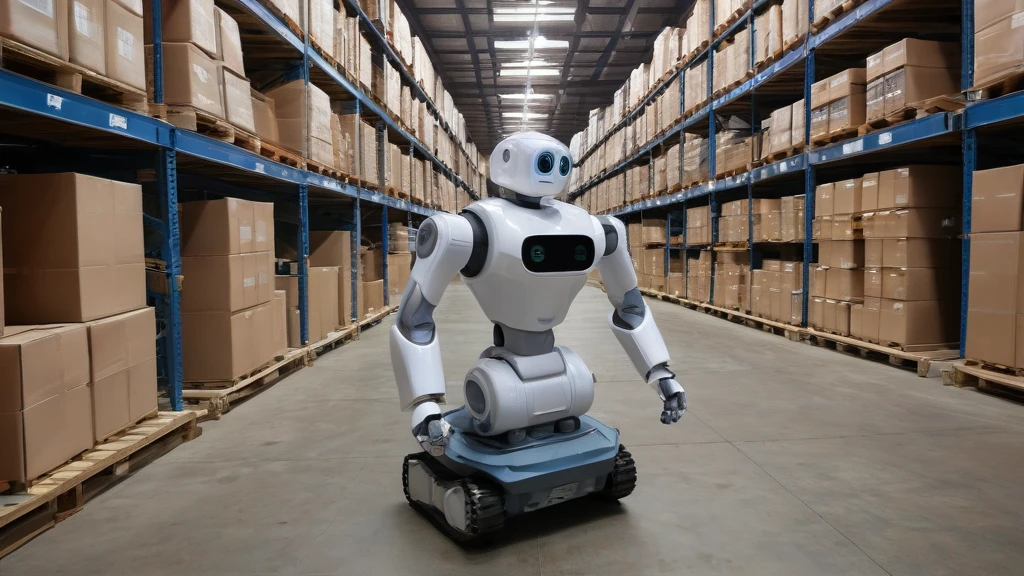
The CT-SAFR (Chain-of-Thought Safety and Faithfulness for Robotics) framework was designed specifically to solve this problem. Its main goal is to ensure the safety and transparency of reasoning in autonomous robots through a multi-layer verification of the decision-making process. In tests conducted on warehouse robots It achieved a false reasoning detection accuracy of 94.2% with a sample size of n = 500 (95% CI: 91.8-95.9%). This means that in over 94 out of 100 cases, the system can recognize when an AI model generates incorrect conclusions.
An important aspect is also its speed. CT-SAFR operates with a latency of less than 500 milliseconds - which allows it to be used in real-time systems without losing efficiency. In the case of warehouse robots that need to react quickly to changing conditions, such latency is completely acceptable and does not negatively affect their performance. Tests confirmed that the framework leads to an 87% reduction in dangerous reasoning outcomes (p < 0.001), which is a significant step towards safe autonomy.
CT-SAFR not only detects errors - it also enables analysis of why a given decision was unsafe. This allows engineers to better understand where and how the AI model "made a mistake," which makes it possible to improve and adapt it to specific working conditions. This is key to the development of systems that are not only safe but also transparent - and therefore can be trusted by people.
 Enlarged imageClose zoomPrevious image
Applications and significance in practical robotics
CT-SAFR has the potential to transform many areas where autonomous robots must make complex decisions. In logistics - e.g., in warehouses - robots often have to assess whether a given path is safe, whether goods can be moved, or whether there is a risk of collision. Without proper reasoning control, even a small error can lead to damage to the load or injury to an employee. CT-SAFR allows for early detection and prevention of such errors.
In medicine, where robots assist in operations or patient transport, transparency of decisions is extremely important. If an AI system suggests a specific action, doctors need to know why it did so - not just that "it works." CT-SAFR can be a key element of such systems, ensuring that the reasoning is reliable and verifiable. This increases trust in the technology and enables faster adoption in clinical practice.
In industry, where robots work in close cooperation with humans, safety is paramount. CT-SAFR can be integrated with monitoring and safety control systems, providing an additional level of protection against incorrect AI decisions. Although the framework has only been tested in one case (a warehouse robot), its architecture is universal - which means that it can be used in different environments and with different types of robots.
Limitations and the future of safe autonomy
It is important not to overestimate expectations. CT-SAFR was presented as a framework for reasoning verification - not as a ready-made product for mass deployment. Its effectiveness has only been confirmed in one test case, on warehouse robots. This means that its operation in other environments - e.g., in outdoor conditions, with changing scenarios or in interaction with humans - requires further research.
Furthermore, the framework does not eliminate all risks associated with AI. It can detect flawed reasoning, but it cannot prevent problems arising from incorrect input data, inaccurate sensors, or improper system design. Therefore, its role is to assist, not replace, engineers and experts in the robot design process.
The future of safe autonomy will depend on solutions that combine advanced AI models with control, transparency, and safety mechanisms. CT-SAFR is a step in this direction: it can not only detect an error but also shows where it occurred. This opens the way for systems that not only work well but are also understandable and trustworthy - which is key to their widespread adoption in industry, medicine, and everyday life.